01 / MECHANICS
Printed in pieces.
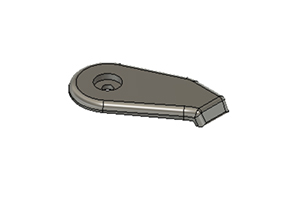
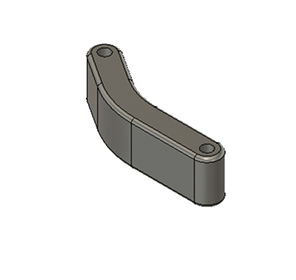
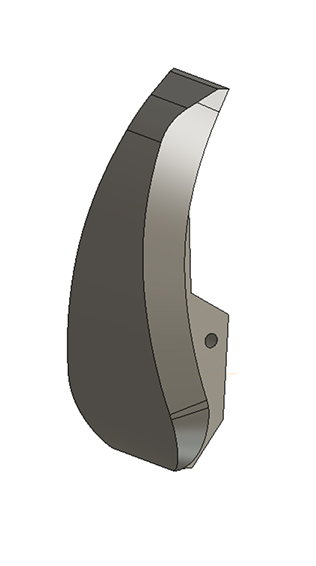
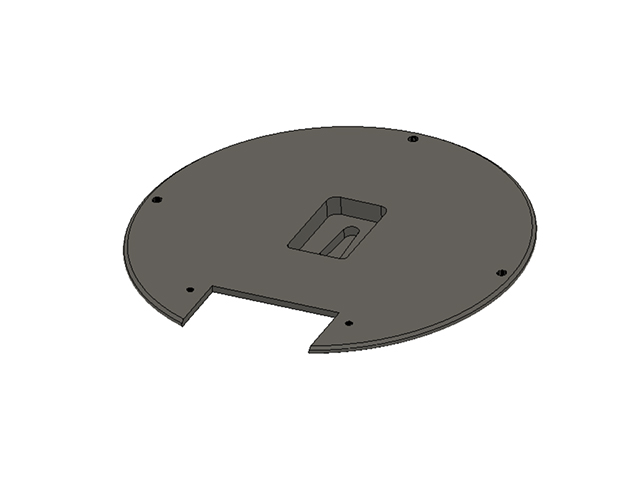
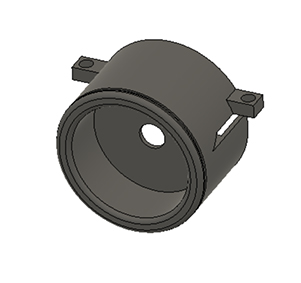
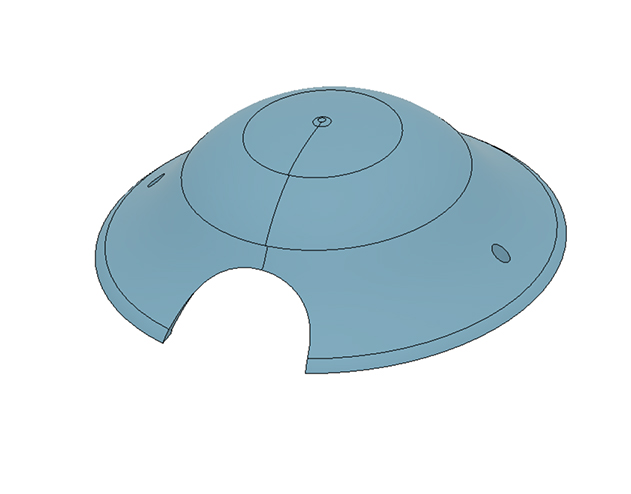
The body, mirrored leg parts, spacers and head have separate design files. That makes the mechanical structure visible, from the central shell to the curved feet.
Built prototype / QUADRUPED · 2-DOF V1
Four legs. A little attitude.
A 3D-printed quadruped with a moving head, eight leg servos, and an ESP8266 at its heart. Meet the original 2-DOF build.
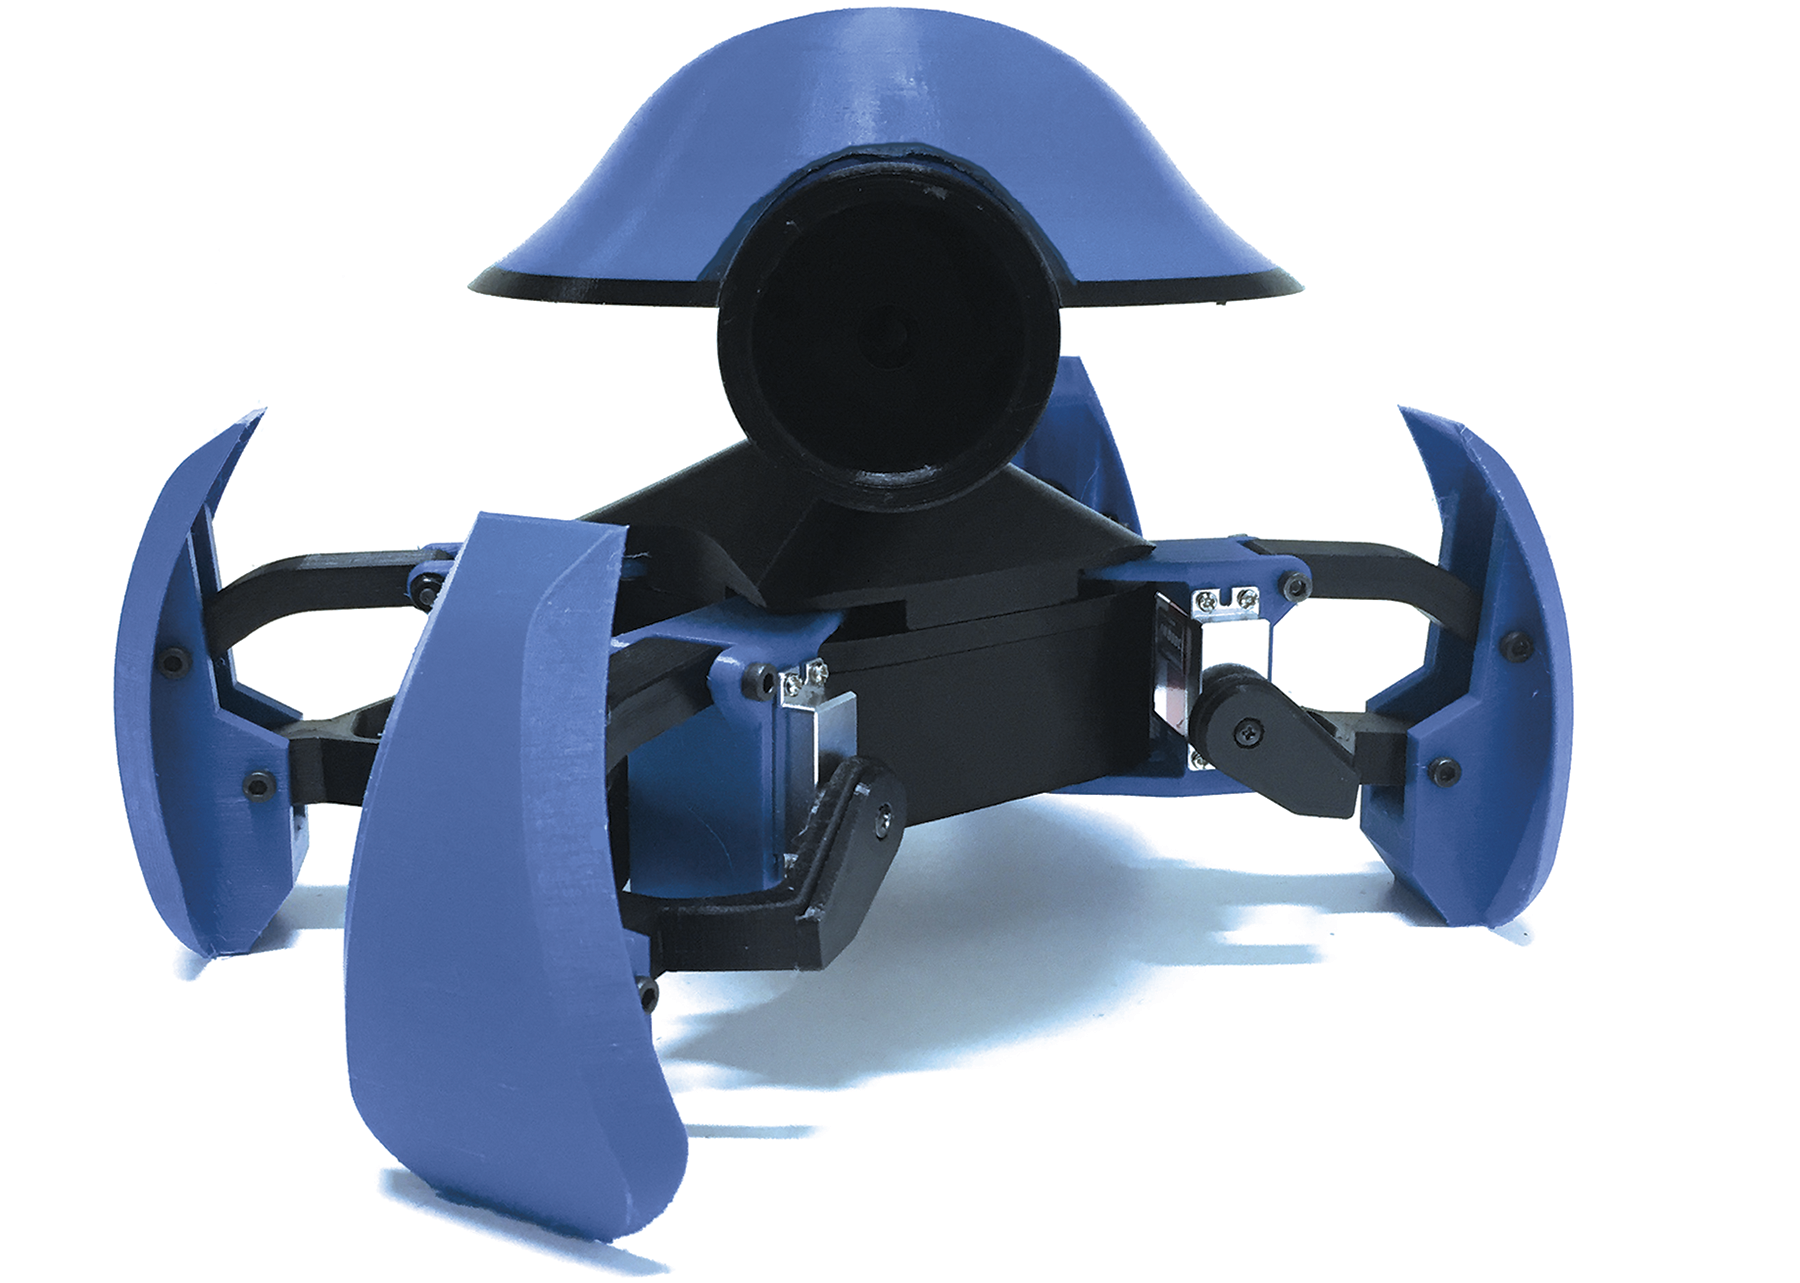
OFF THE SCREEN. ON ITS FEET.
FROM THE 2018 WORKBENCH
iOlly brings a compact four-legged body together with a large, rounded head and curved feet. The original photographs, prints and motion demo show the design making the jump from CAD to a physical robot.
This page follows the documented 2-DOF v1 build: two driven joints in each leg, plus a separate head channel. Its character comes from the combination of its silhouette, stance and programmed movements.
FROM MODEL TO MAKER
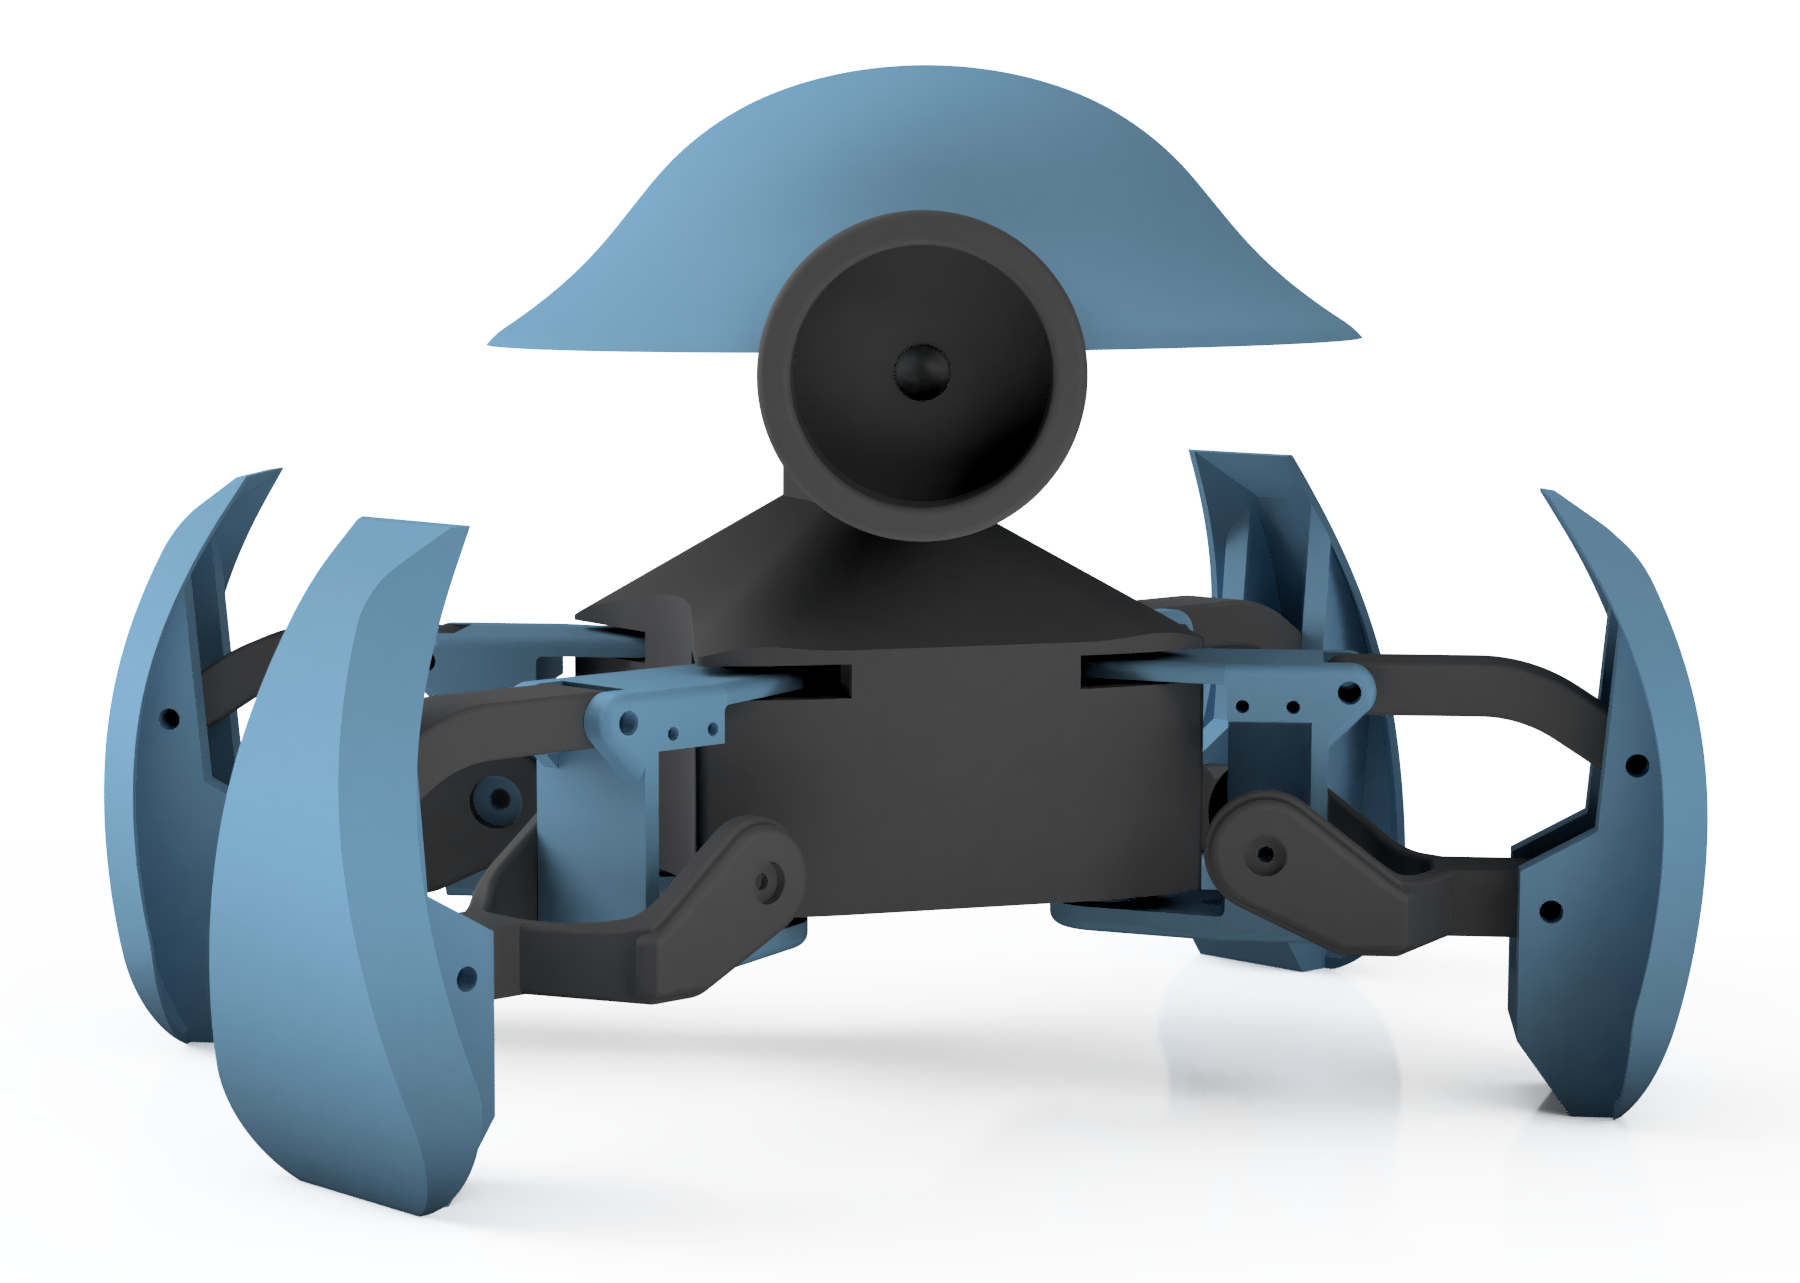
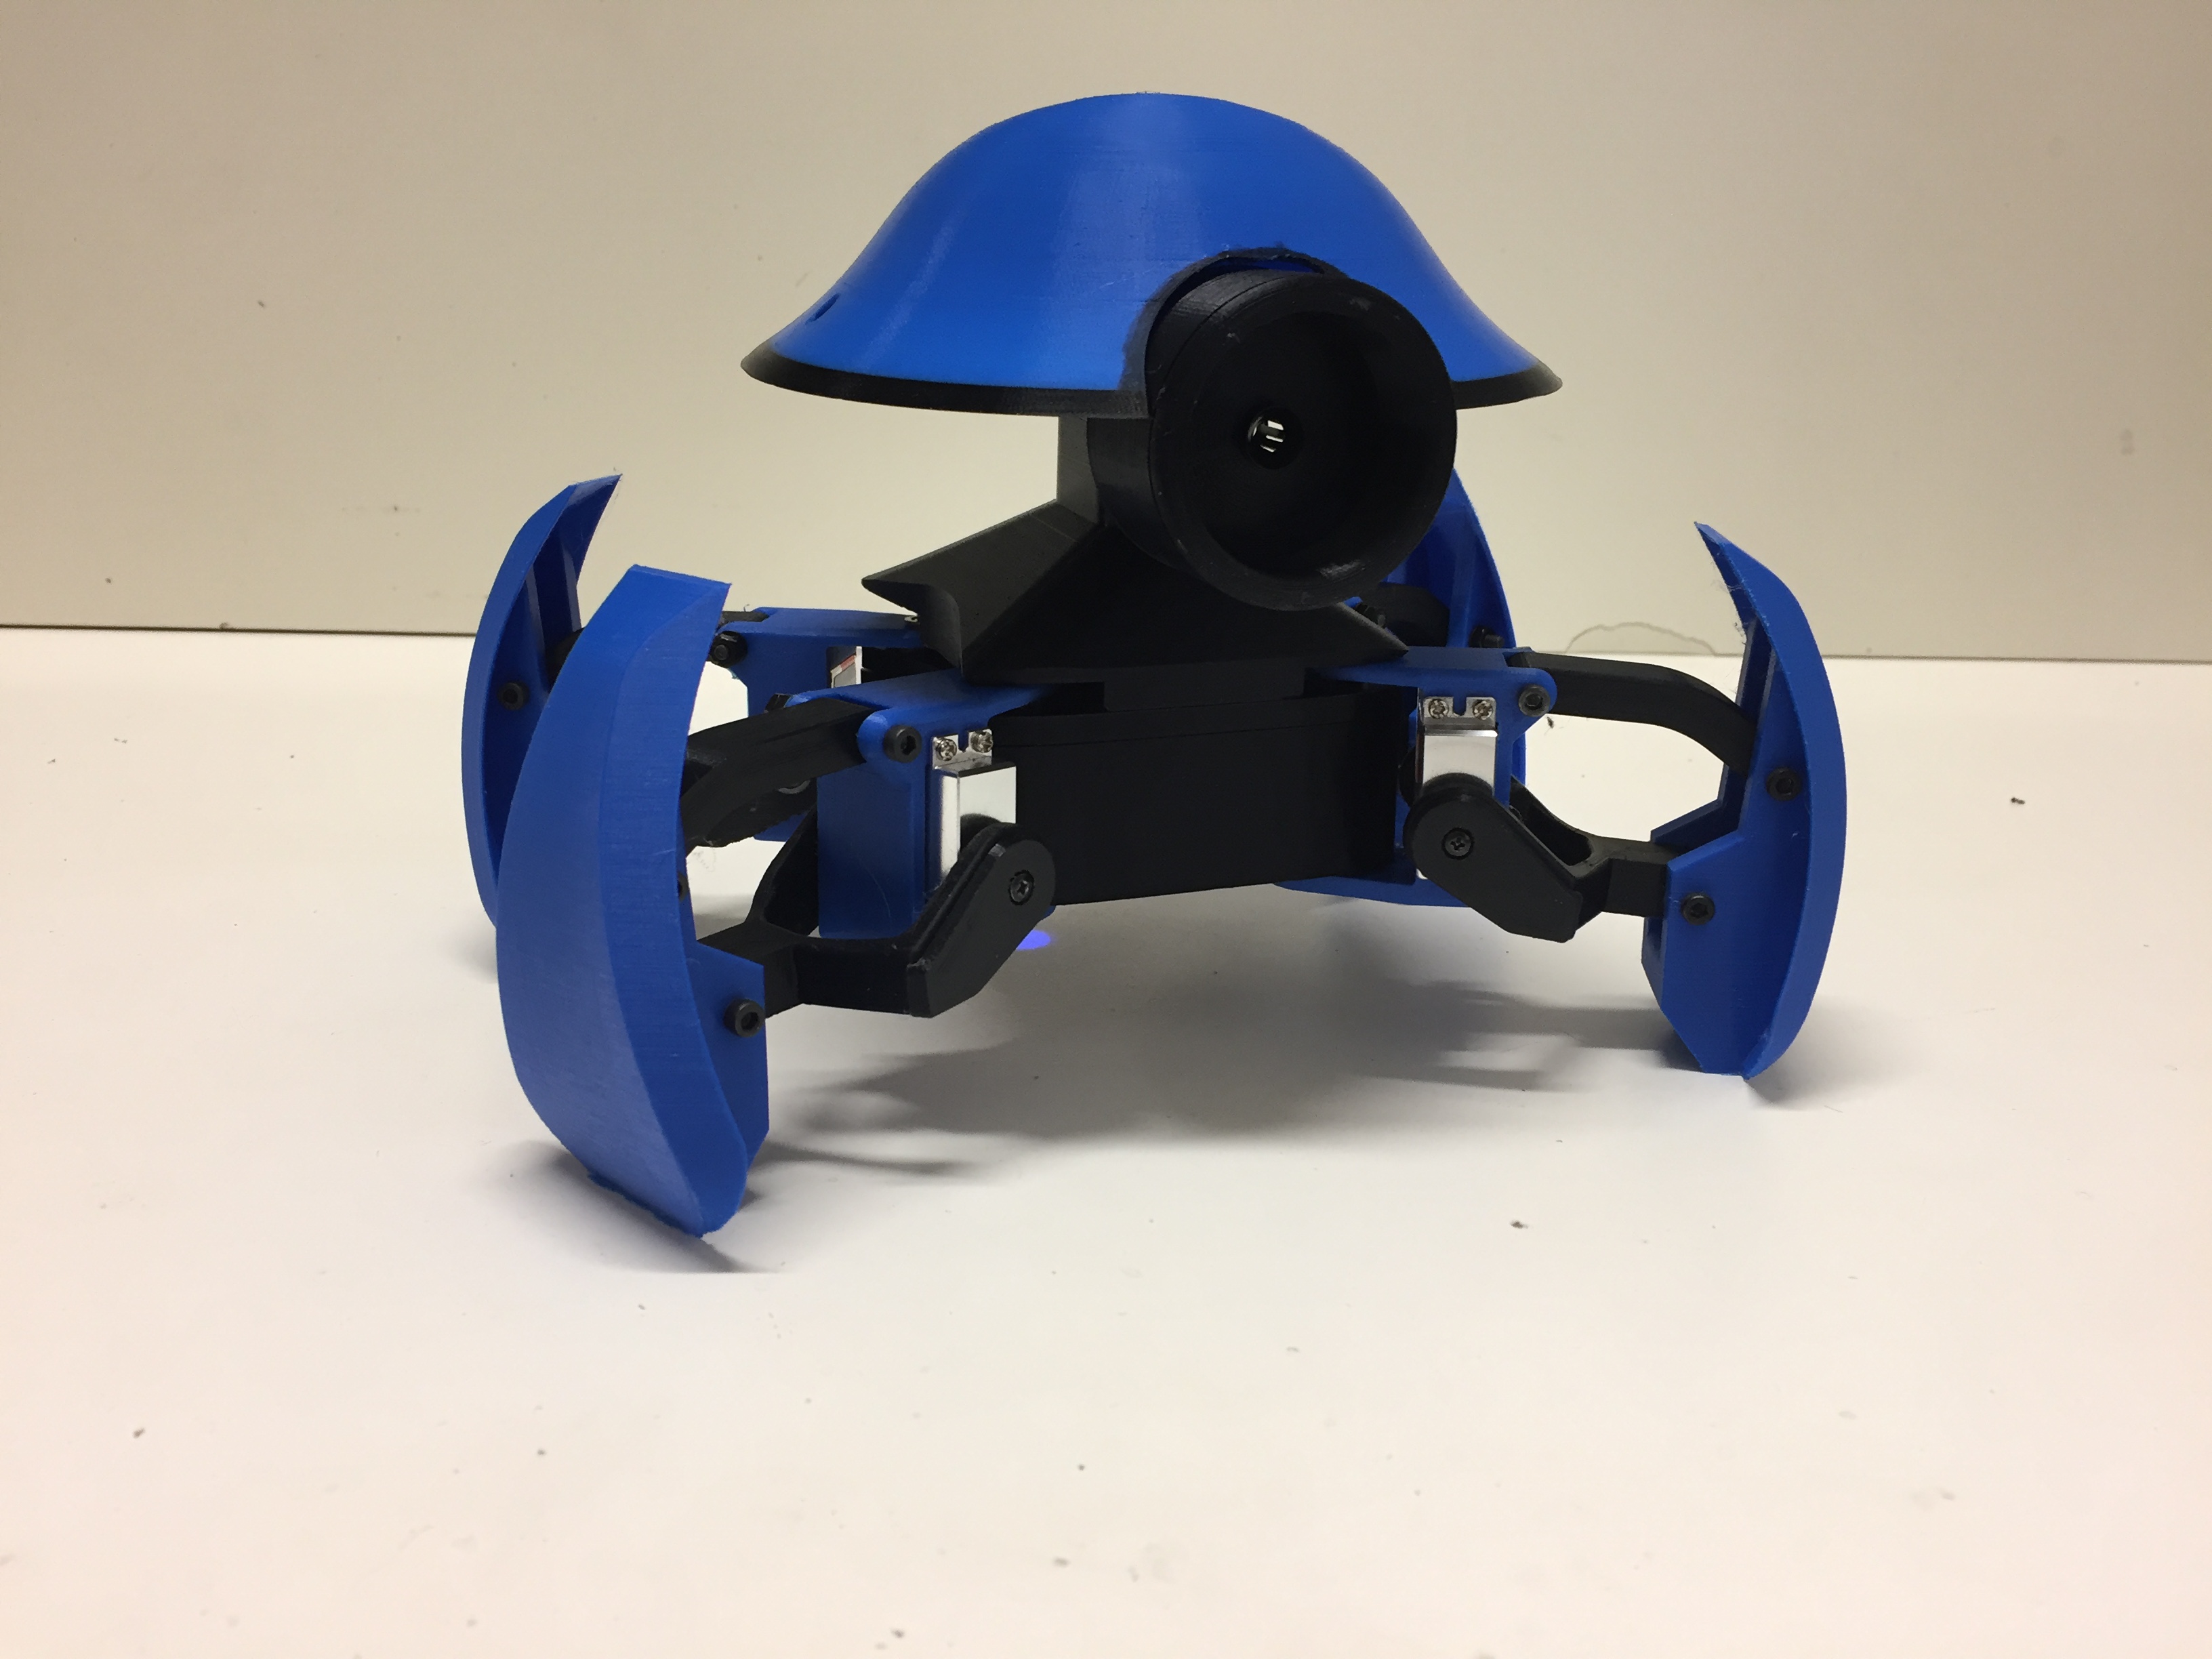
The body, mirrored leg parts, spacers and head have separate design files. That makes the mechanical structure visible, from the central shell to the curved feet.
The archived firmware defines walking and turning alongside poses and gestures such as hello, looking around, nodding and dancing.
An ESP8266 handles the original command interface. Movement requests are received over a local wireless connection and passed to the motion routines.
The movement list describes the archived firmware. Each routine has not been re-tested for a new release. The front piece is named “camera” in the files; camera hardware and vision functionality are not established by this archive.
A CLOSER LOOK / 2-DOF V1
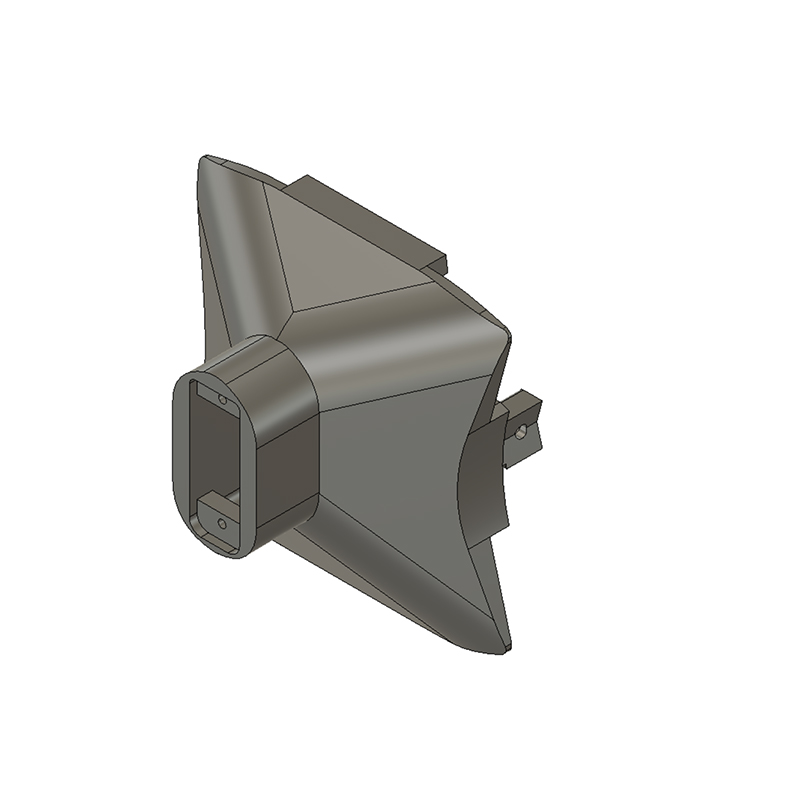
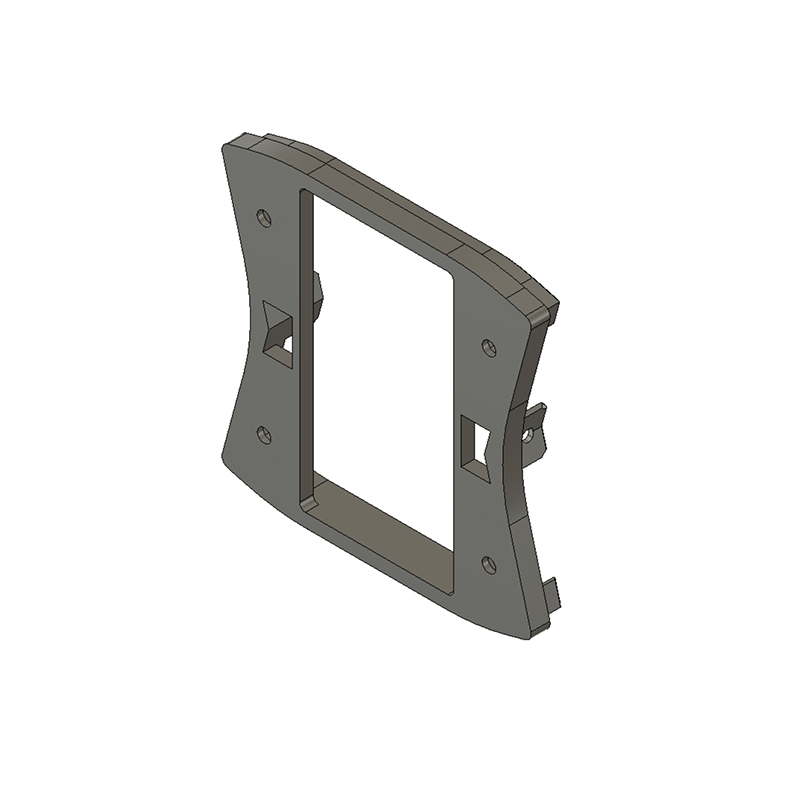
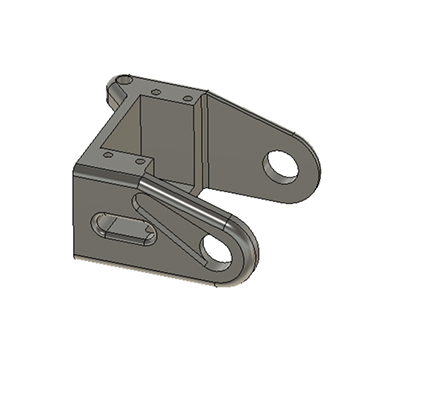
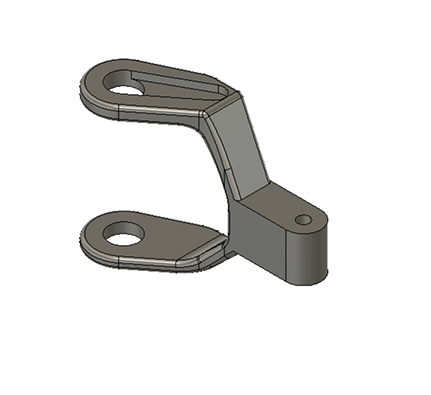
The original component views show how the body, joints and head are divided. Open a drawing for a closer look. These are reference illustrations; the complete STL package is not released here yet.
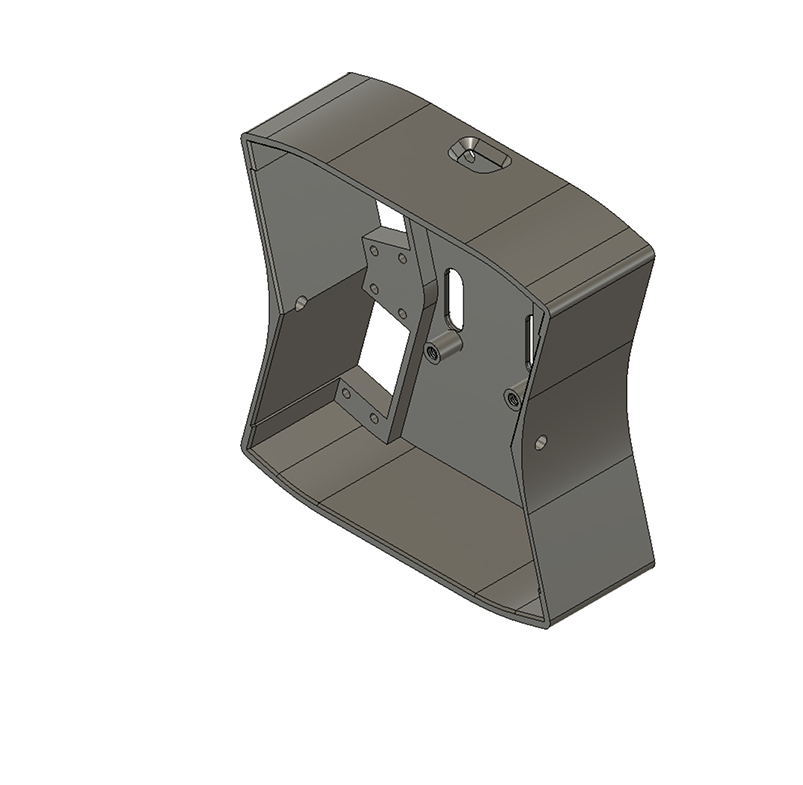
UNDER THE SHELL
The v1 source configures eight leg outputs and a ninth head output. The body’s motion is coordinated by servo oscillators; commands select the movement or pose.
Exact servo models, the power supply and a verified wiring diagram still need documenting before this becomes a reproducible build guide.
THE PROJECT NOTEBOOK
Prototype photographs, a demonstration video, component drawings, a 16-file STL set and Arduino C++ source document this version. The STL set includes a separate tibia print-layout file; 16 files does not mean 16 pieces per robot.
The orange-and-black 4-DOF quadruped has its own prototype and progress videos. Its 11 component drawings, including the neck, tars and battery cover, now have a home on its dedicated project page.
Meet iOlly 4DOFBUILD YOUR UNDERSTANDING
Explore the mechanical file set, original print profile, servo-channel map and movement commands. The notes explain what the archive tells us and what still needs checking for a complete guide.
Read the iOlly build notesPLANS & FILES
The original design files are being documented for a future release. A checked build package, download contents and any pricing will be announced here when ready.
STL archives, firmware downloads and purchasing are not available on this site yet.
Back to the workbench